Guided Hand Manipulation Via Surface Contact And Control
The Hidden Details of Guided Hand Manipulation Via Surface Contact And Control Revealed
Overview of Guided Hand Manipulation Via Surface Contact And Control
We propose a contact - guided adaptive density control strategy to effectively address self-occlusions and object occlusions, as well as a time-dependent refinement module that precisely captures complex surface deformations for accurate contact estimation and dynamic reconstruction.
Guided Hand Manipulation Via Surface Contact And Control
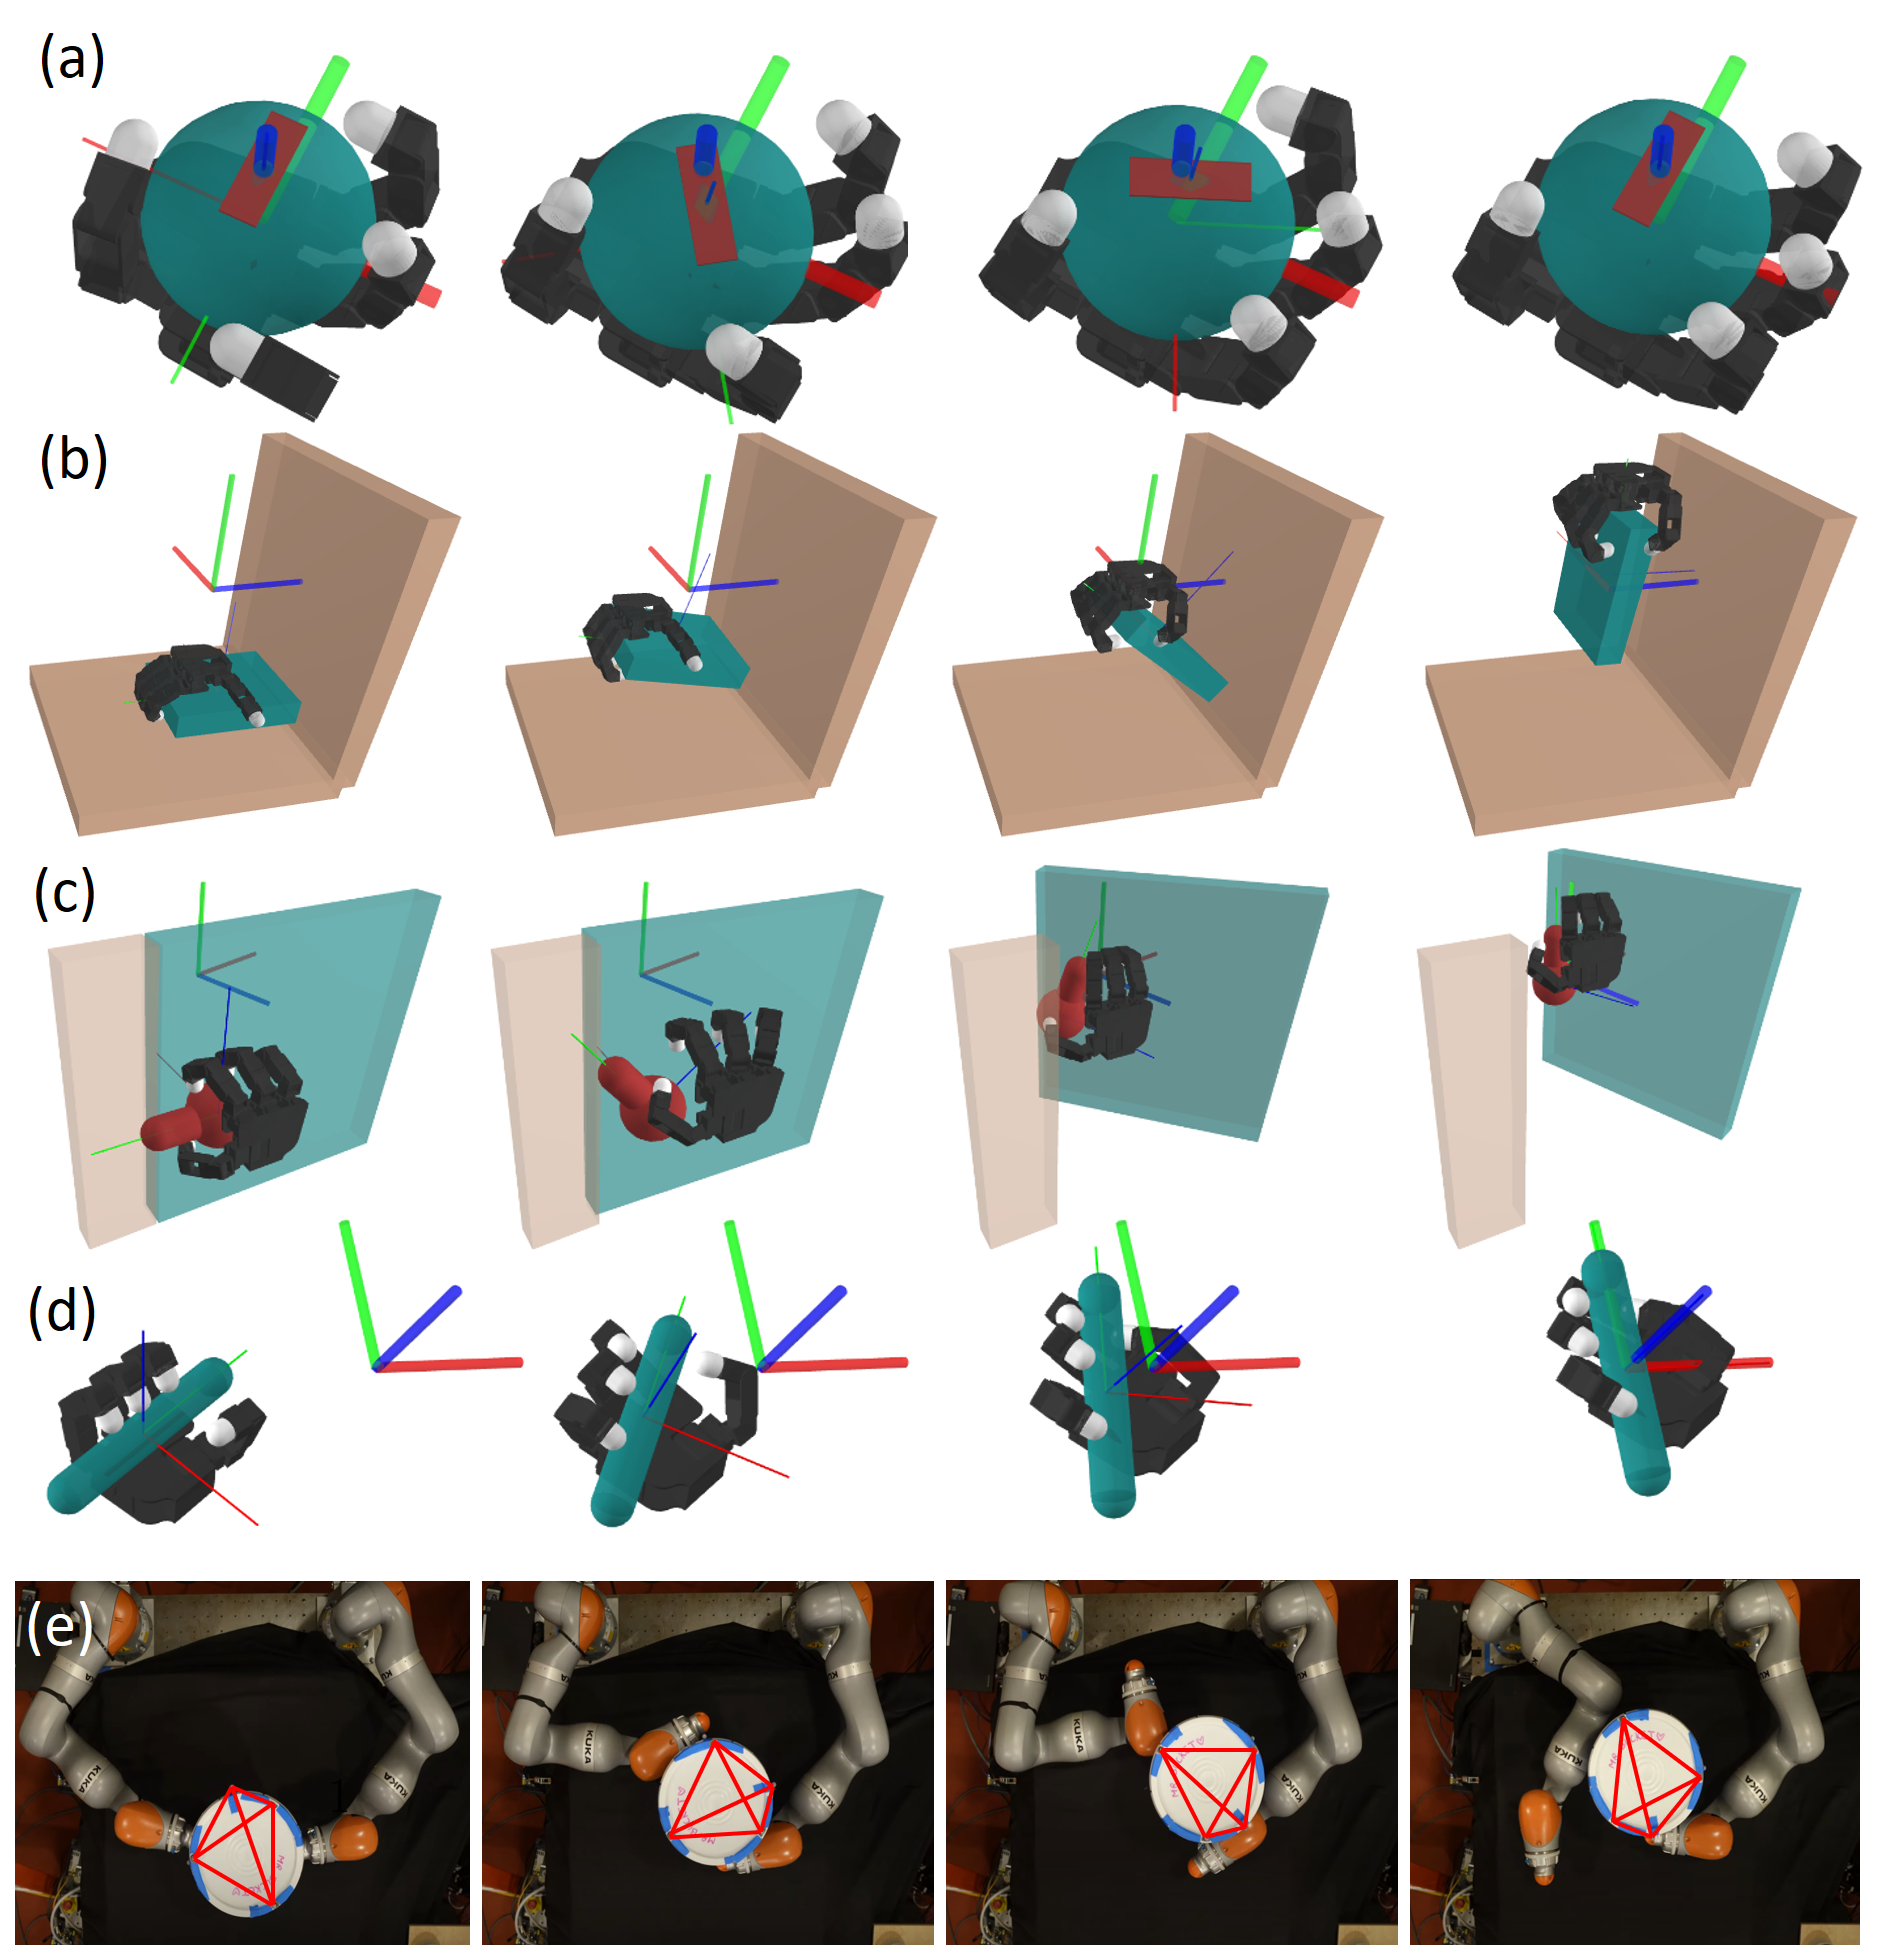
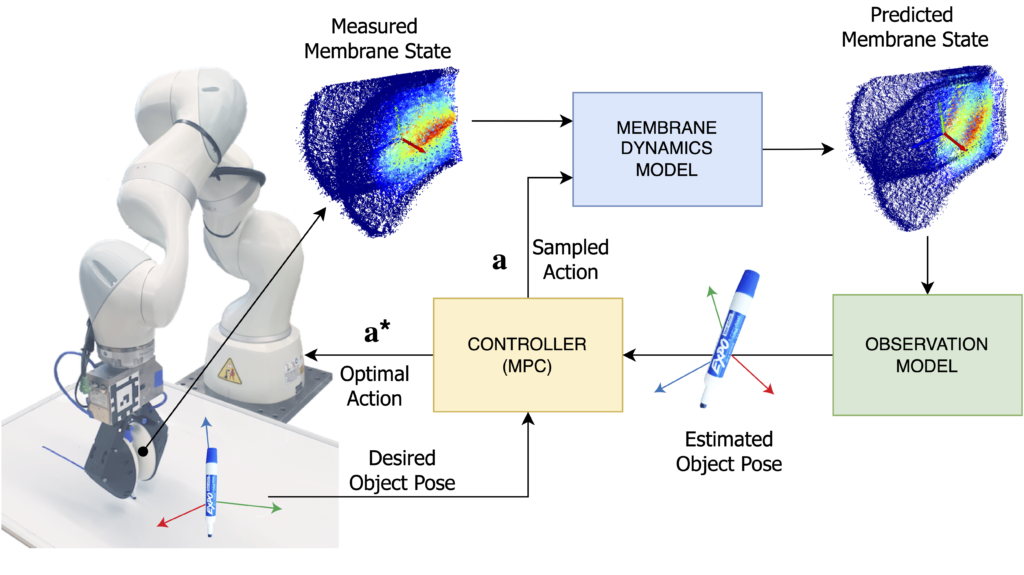
Progress has been limited by the lack of large-scale, contact -aware non-prehensile datasets for dexterous hands and the absence of wrist-finger control policies. To bridge these gaps, we present DexMove, a tactile- guided non-prehensile manipulation framework for dexterous hands .
Guided Hand Manipulation Via Surface Contact And Control
Moving forward, it's essential to keep these visual contexts in mind when discussing Guided Hand Manipulation Via Surface Contact And Control.
A single
Guided Hand Manipulation Via Surface Contact And Control
We propose a novel two-stage policy learning framework BBE (Basics-before-Extension) that enables complex dexterous multi-fingered hand grasp and manipulation using only one human demonstration per task, by explicitly extracting and structurally learning key expert skills — hand -object contact points.
Integrating Contact, Modeling, and Control for the Robotic Hand ...
A novel manipulation control framework is proposed for the dexterous robotic hand , which integrates the constraints ( contact constraints and servo constraints), dynamics modeling and controller design. In the manipulation task, the contact between the robotic hand and the target object translates the manipulating force and constraints the relative motion of the target. Hence, the contact ...